
AgentSTAR is an agentic method for both reconstruction and tracking of articulated objects from monocular videos. We can now track through rapid motion, severe occlusion and thin objects! There’s no spoon but we can still track it 🥄
0:54

PhD student at Dyson Robotics Lab @ Imperial College London
AgentSTAR is an agentic method for both reconstruction and tracking of articulated objects from monocular videos. We can now track through rapid motion, severe occlusion and thin objects! There’s no spoon but we can still track it 🥄
Wrote done my thoughts on what's fundamentally new for vision when using agents --- obviously, apart from some hard problems that have now been nearly solved :)

I wonder if something like this could be used for Star Wars fan films to track 3d lightsabers instead of using roto🤔
I particularly like this example, where we show our reconstruction alongside the ground-truth hand poses -- it gives a much better sense of the 3D tracking accuracy
In my mind, this line of thinking was popularised by Real2Code and SceneScript, but can now finally be taken to the extreme, where code is not only the representation but also what gets the tracking done
For more visuals and details check out our project page, paper and code release! Real2Sim for dynamic scenes is definitely within reach now joint w/ @n_karaev Matthew Chang @JitendraMalikCV @notmahi Project page: agenticstar.github.io Code: github.com/makezur/agenticST…

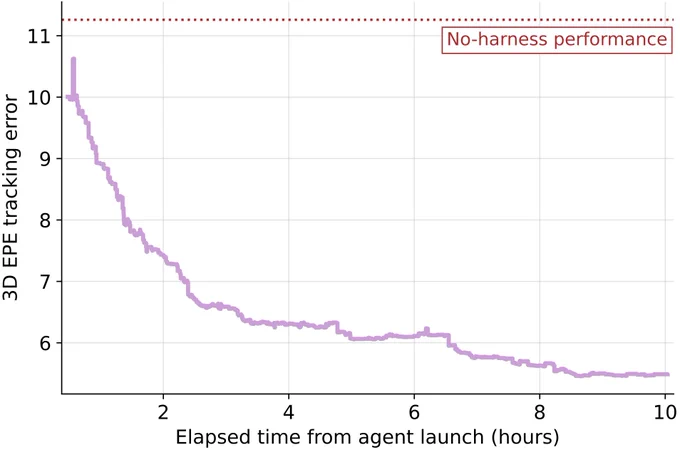
With the right tools and enough inference time, even previous-generation VLM agents can outperform established 3D tracking methods on both dynamic and rigid objects. This plot shows tracking quality as agentic optimisation progresses over time for GPT-5.6 Sol as a base model.
AgentSTAR is a harness: a set of tools and protocols that lets agents jointly refine object shape and pose while staying temporally consistent even for symmetrical objects. Here, you can see both the shape and pose being refined across two video frames:

I'll be presenting our work at #ECCV2026 in Malmö! 🇸🇪 Find me at the poster and demo sessions: Poster 📅 Thu 10 Sep, 10:30 📍 ExHall #272 Demo 📅 Sat 12 Sep, 8:00 📍 ExHall Also at NeuSLAM Workshop 🤖: Tue 8 Sep, 14:00, Malmö Arena Hotel
(1/3) I am happy to share our work on Triangle Splatting SLAM! We show the first RGB-D SLAM to use differentiable triangles as a 3D map representation. Our method enables online mesh-based deformations and collision checking via on-the-fly Delaunay triangulation.

Just announced: #CVPR2026 Best Demo Award for KV-Tracker. Congrats to Marwan and co-authors. And thanks to @deepfry_n, @shinjeong99 for massive help running the demo. That's 4 CVPR Best Demo Awards/Honourable Mentions in 3 years for our lab at Imperial! Proud of our demo culture.
How can we run reconstruction models like π³ and Depth Anything 3 in real-time? We present KV-Tracker, a training-free approach, for real-time tracking of scenes and objects. Achieving up to 30 FPS! With @alzugarayign, @makezur, @XinKong_IC and @AjdDavison

Wanna see a real-time demo of KV-Tracker? Stop by in ExHall F today 11:45 - 13:45! #CVPR2026
code is released too: github.com/makezur/4D_PM project page: makezur.github.io/4DPM/

How to build complete 4D reconstructions from videos? Swing by 4DPM oral presentation today: Mile High Ballroom 3A - 4A, 13:00 #CVPR2026
4DPM got selected for an oral presentation at #CVPR2026 🤠
Introducing 4D Primitive-Mâché (4DPM), a new method for replayable 4D reconstruction from monocular videos. We split dynamic scenes into 3D primitives and recover their motion. 4DPM can infer object positions even after they leave view. Joint work with @marwan_ptr @AjdDavison
accepted to #CVPR2026 😎
Introducing 4D Primitive-Mâché (4DPM), a new method for replayable 4D reconstruction from monocular videos. We split dynamic scenes into 3D primitives and recover their motion. 4DPM can infer object positions even after they leave view. Joint work with @marwan_ptr @AjdDavison


